SYS_ID: 001  |  ROBOTICS · REINFORCEMENT LEARNING  |  IPAB · UNIVERSITY OF EDINBURGH

NalinAgarwal

Research Assistant · IPAB, University of Edinburgh

Physics-trained. Robot-focused. I build intelligent agents that move, sense and adapt, from robot kinematics to learned control policies. MSc AI at Edinburgh, 2025-2026. SLMC group, IPAB. Earlier research at IIT Delhi and ISRO.

nalin@robotics-lab ~
$ 
Research Assistant · IPAB, UoE
Edinburgh, Scotland 🏴󠁧󠁢󠁳󠁣󠁴󠁿
$ 
Focus: Robot Learning · RL Policies · Motion Planning
Tools: Pinocchio · Python · C++ · Linux
Prior: ISRO · IIT Delhi · C-DAC
$ 
[2026] arXiv:2610.23438
Blind Baoding, Shadow Hand
[2024] IEEE ICITEICS · Novel DG MOSFET
[2022] TROPMET · Marine Heatwaves & Cyclones
$ 
ACTIVE · Research Assistant at IPAB, UoE
click terminal or press ~ to go interactive
physics_sim · double_pendulum.pydrag a bob & fling it
NALIN AG.ROBOTICS · RL
About

Physics-trained.
Robot-focused.

/* background */

I'm a Research Assistant in the Statistical Machine Learning and Motor Control (SLMC) group at IPAB, University of Edinburgh, focused on robot learning, dexterous manipulation, tactile sensing and sim-to-real reinforcement learning. My background in AI and Engineering Physics brings together mathematics, signal processing and dynamical systems. I apply that foundation to teaching robots how to move, perceive and make decisions.

/* what drives me */

I'm drawn to embodied intelligence: agents that act in the physical world under uncertainty. From processing satellite data at ISRO to computational ocean analysis at IIT Delhi, I've always worked at the edge of computation and physical systems. Robotics is where those worlds meet permanently.

/* beyond the lab */

I've built web apps, competed in science hackathons (Top 20 nationwide in XR-tech), and led teams. I believe the best engineers are curious generalists who execute with precision.

MSc Artificial Intelligence
University of Edinburgh, Scotland
2025-2026 · Merit (70.6%)
Robotics & reinforcement learning
Coursework

Advanced Robotics; Robot and Reinforcement Learning; Probabilistic Modeling and Reasoning; Advanced Topics in Machine Learning; Computational Neuroscience; Computational Cognitive Neuroscience; Introduction to Quantum Computing; Computer Vision.

£5,000
India Merit ScholarshipUniversity of Edinburgh
BTech Engineering Physics
Delhi Technological University, India
2020-2024 · GPA: 9.18 / 10
Electronics & Communications major · Computer Science minor
Coursework

Fundamental Physics; Mathematics; MATLAB Applied Physics; Quantum Physics; Cosmology and Astrophysics; Electronics; Semiconductors; Optical Fibres; Microwave; Atmospheric Sciences; Data Structures and Algorithms; Database Systems; Operating Systems; Computer Networks; Computer Graphics.

CS50X · Harvard University
Online Certificate
Current research

On the lab bench.

SLMC / IPAB / UoE · OCT 2026-PRESENT

Simulation, control and robot interfaces for manipulation. Current research in the Statistical Machine Learning and Motor Control group at the University of Edinburgh.

01 / SIMULATEMuJoCo

Real-time environments & object resets

02 / TUNEController gains

Parallel sweeps with mjbatch

03 / EXECUTEROS2

Trajectories, teleoperation & cameras

01 / SIMULATIONONGOING

Robotic box folding.

MuJoCo simulation infrastructure for real-time box folding, object-state resets and trajectory execution. Controller-gain tuning and parallel parameter sweeps with mjbatch connect simulation to reinforcement-learning and data-collection pipelines.
MuJoComjbatchManipulation
02 / ROBOT INTERFACESONGOING

NEXTAGE execution.

ROS2 interfaces for trajectory editing and folding execution on NEXTAGE. Streaming teleoperation and simultaneous publishing from multiple robot cameras support interaction and data collection.

NEXTAGEROS2Teleoperation
03 / MODEL & CONTROLONGOING

AIREC integration.

MuJoCo model integration and controller stabilisation for the AIREC robot. A focus on the simulation and control foundations needed for reliable robot behaviour.

AIRECMuJoCoControl
Trajectory

$ git log --career

a6f012bHEAD → edinburgh/ipabOct 2026 - Present · Full-time
feat(research): Research Assistant @ IPAB, UoE
SLMC group, IPAB. MuJoCo box-folding infrastructure, controller tuning, ROS2 interfaces for NEXTAGE, and AIREC model integration. Current projects →
f7c2a91tag: MSc-AI2025-2026
study: MSc Artificial Intelligence @ University of Edinburgh
Advanced Robotics, Robot & Reinforcement Learning, Probabilistic Modelling and Computational Neuroscience.
e3b112atag: ICRA-2027tag: CoRL-2026-WSJan-Sept 2026
feat(dexterous): blind Baoding on the Shadow Hand Lite · MSc dissertation
Sim-to-real RL with proprioception + binary touch, no vision. 112.5 rotations on hardware. Under review at ICRA 2027 and two CoRL 2026 workshops. see project →
d84b3e0Nov 2024 - Mar 2025
feat(quantum): hybrid quantum CNNs for wildfire detection @ C-DAC Pune
Research Assistant. QAOA, VQE, IBM Qiskit & PennyLane · quantum ML for image-based wildfire recognition.
9e1fa55tag: IEEE-2024Jul 2024
publish: novel DG charge-trapping MOSFET → IEEE ICITEICS-2024
Ferroelectric gate stack + Gaussian doped substrate. DOI: 10.1109/ICITEICS61368.2024.10625402
b52c7d8Feb - Oct 2024
feat(ocean): Seychelles-Chagos thermocline ridge analysis @ IIT Delhi
Part-time research fellowship at the Centre for Atmospheric Sciences, supervised by Dr. Samiran Mandal. Heatwave hotspots and IOD/ENSO correlations.
7a90c13tag: TROPMET-2022May-Jul 2022 · Jun-Aug 2023
feat(satellite): marine heatwave detection tool @ ISRO · Space Applications Centre
Two research stints. Real-time global MHW detection over 40 years of satellite data; cyclone correlation study presented at TROPMET-2022.
3c4e6b2tag: CS50xNov 2023
cert: CS50x @ Harvard University
Because every roboticist should know how the stack actually works.
0000001Dec 2020 - May 2024
init: BTech Engineering Physics @ Delhi Technological University
GPA 9.18/10. ECE major, CS minor. The physics foundation everything else is built on.
Skills

Toolkit.

Languages
PythonC / C++MATLABSQLLaTeXHTML / CSSJavaScript
Robotics & Simulation
ROS / ROS2Isaac LabMuJoCoPinocchioMotion PlanningSLAM (learning)
Learning & Cognition
PyTorchReinforcement LearningPPOSACComputer VisionProbabilistic ModellingComputational Neuroscience
Hardware & Control
Tactile SensingArduinoMicrocontroller InterfacingRobot Control
Quantum & Scientific
QiskitPennyLaneQuantum MLSilvaco TCADATLASSatellite Data AnalysisSemiconductor Physics
Software & Creative
GitLinuxFlaskJinjaGodotUnityAdobe Creative Suite
Projects & Research

Work.

▶ 112.5 ROTATIONShardware video · uploading soon
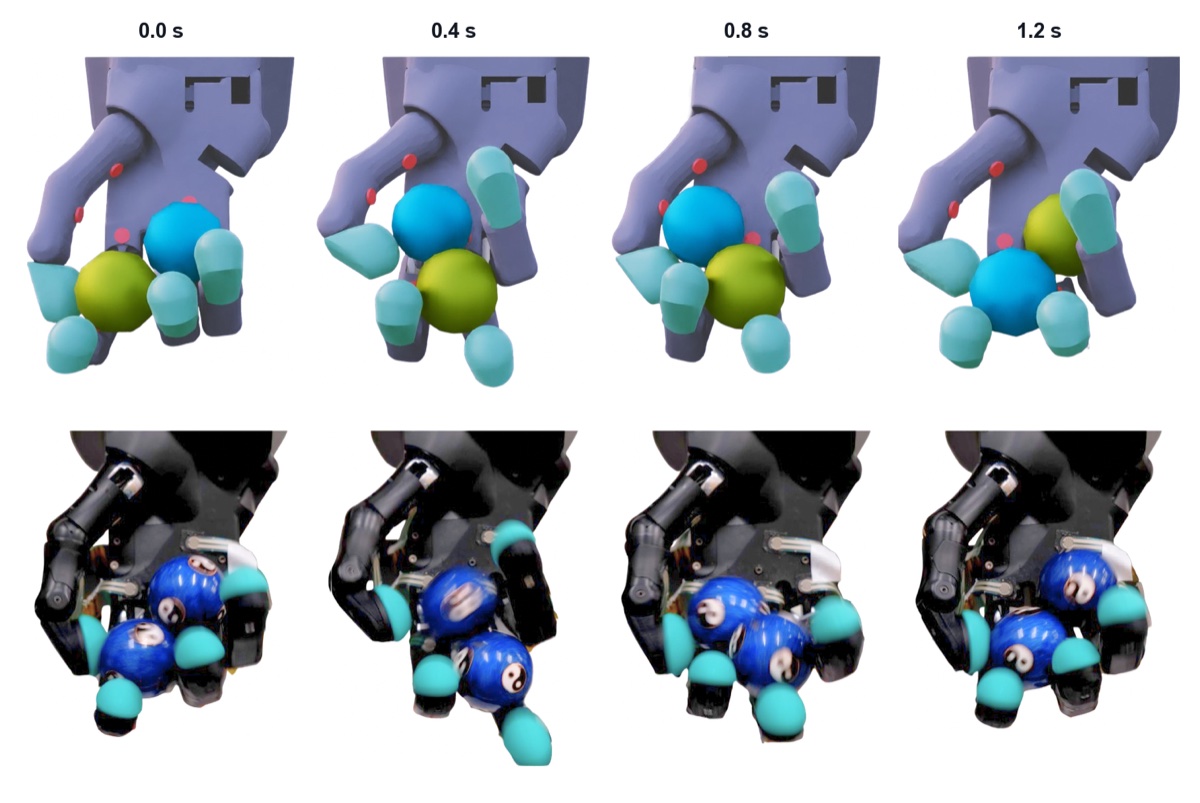
// hardware run · the policy keeps two Baoding balls cycling for 112.5 rotations, blind
Simulated (top) and hardware (bottom) Shadow Hand Lite rotating two Baoding balls under the same policy, frames at 0.0, 0.4, 0.8 and 1.2 seconds
// top: simulation · bottom: matched hardware frames, same policy, zero-shot
MSc Dissertation · ICRA · CoRL
00 · University of Edinburgh, 2026
No Eyes, No Problem: What Does Touch Contribute to Blind Baoding Ball Manipulation?
A reinforcement-learning policy rotates two Baoding balls on a Shadow Dexterous Hand Lite using proprioception and binary touch, without cameras. Sensor-aligned simulation, tactile calibration and domain randomisation enable zero-shot transfer to the real hand. The project studies what touch contributes to sustained manipulation and which regions of the hand matter most.
112.5peak full rotations on hardware
34.75mean full rotations · 10 trials
16tactile sensors · 12 FSR + 4 BioTac
60 HzPPO policy deployment
Method & dissertation details

The tactile system combines 12 FSR sensors and four BioTac fingertips with per-channel hysteresis calibration. PadTac USD assets in Isaac Lab, a ROS deployment pipeline and slew-rate domain randomisation account for sensing and hardware motion limits. PPO policies transfer zero-shot to the physical hand.

MSc dissertation, Jan-Sept 2026: Development of a Low-cost Tactile System for Dexterous Manipulation and Investigating the Sim-To-Real Gap in Tactile Reinforcement Learning.

Supervision: Prof. Sethu Vijayakumar and Elle Miller.

Authors: Ayush Deshmukh*, Nalin Agarwal*, Elle Miller, Sethu Vijayakumar.
*Equal contribution.
Dexterous ManipulationSim-to-RealTactile SensingReinforcement LearningDomain RandomisationROS
arXiv preprint · ICRA 2027Under review
No Eyes, No Problem: What Does Touch Contribute to Blind Baoding Ball Manipulation?
CoRL 2026 workshops
No Eyes, No Problem: Zero-Shot Blind Baoding Ball Manipulation with Binary Touch
Project pagedemo, method, and results
03 · ISRO, 2022-23
Marine Heatwave Detection via Satellite
Tool for real-time marine heatwave detection worldwide using 40 years of satellite observations. Analysed MHW metrics and correlations with cyclone activity in the Indian Ocean under Dr. Rashmi Sharma and Dr. Nitant Dube. Research visits: May-Jul 2022 and Jun-Aug 2023.
PythonSatellite DataISRO
TROPMET 2022 presentation

On Rapid Increase In The MHW Intensity During Last Decade (2010-Present) Using Satellite Observations: Implications on Cyclone Activity in the Arabian Sea?

Nalin Agarwal, Nitant Dube, Rashmi Sharma.

Presented at IISER Bhopal, December 2022.

↗ Presentation certificate
04 · IIT Delhi, 2024
Oceanic Analysis · Seychelles-Chagos Thermocline Ridge
Computational analysis of oceanic heatwave hotspots in the Southern Indian Ocean. Correlated sea surface height and chlorophyll anomalies with IOD/ENSO events, under Dr. Samiran Mandal at the Centre for Atmospheric Sciences.
PythonOceanographyIIT Delhi
05 · Personal
Gamer's Paradise
A web app for organising gaming libraries. Add, delete, search and curate personalised playlists. Built with Flask, SQL, and a clean HTML/CSS/JS frontend.
FlaskSQLHTML/CSSJavaScript
06 · Personal
Cricket Scorecard DBMS
Database management system for cricket scorecards in C++. Store, retrieve and edit scorecards with full CRUD support. Your own personal Cricbuzz.
C++DBMSData Structures
People, design & community

Beyond the lab.

DESIGN / LEADERSHIP

Ideas need a visual language.

Leading design teams and shaping print and digital work, from brochures and event identities to websites and social media graphics.

Ambassador of DesignHEIV, the scientific community
Design HeadThe Indian Game Theory Society
Design HeadSociety of Robotics, DTU
Design HeadDEPTH, Engineering Physics Society
MUSKURAHAT FOUNDATIONMAY-AUG 2023

Fundraising with purpose.

₹8,000raised as a volunteer

Fundraising, awareness drives and conversations about the foundation's work for children in India.

↗ Volunteer certificate
EDUMONICSJUN-OCT 2021

Research, written for people.

Content research and corrections, blog posts, website landing pages and digital marketing with SEO. Turning research into clear communication and accessible web content.

↗ Content research certificate
EARLY MILESTONES

School topper in Class X board examinations · Academic Head Boy in Class XII

Research horizon

Beyond learned behaviour.

LONG-TERM GOAL · EXPLORATORY

Consciousness &
self-awareness.

My long-term goal is to build embodied systems that could develop subjective experience and a sense of self. I want to understand how consciousness and self-awareness could emerge through perception, memory and action.

I want to explore agents that build a model of themselves, reflect on what they know and learn through experience in the physical world. Robotics gives me a way to connect those questions to perception, action and learning.

Research notes and experiments coming soon.
A brain illustrated with teal neural connections and warm amber circuit traces
PERCEPTION / MEMORY / SELF-MODEL

Upcoming explorations

STATUS: PLANNED
01 / SELF-MODELSPlanned

An agent that models itself.

Explore how an embodied agent could learn the relationship between its body, its actions and the world around it.

Embodiment · Internal models
02 / MEMORYPlanned

Experience that carries forward.

Investigate how memory and a continuing history of experience could shape an agent's model of itself over time.

Memory · Learning over time
03 / METACOGNITIONPlanned

Knowing what it doesn't know.

Study how agents might track uncertainty, recognise their own limits and use that information to guide learning.

Uncertainty · Reflection
Contact

Let's build
something that moves.

If you're working on robotics, robot learning or RL, I'd love to hear from you. I bring a physics and systems thinking background to research and collaboration.

~ terminal G game
RL-GRIDWORLD v1.0 · TRAIN THE ROBOT
Reach the goal ◆. Arrow keys / WASD to move · or press AUTO-TRAIN and watch Q-learning do it.
EPISODE 0 STEPS 0 REWARD 0 ε 1.00 MODE HUMAN