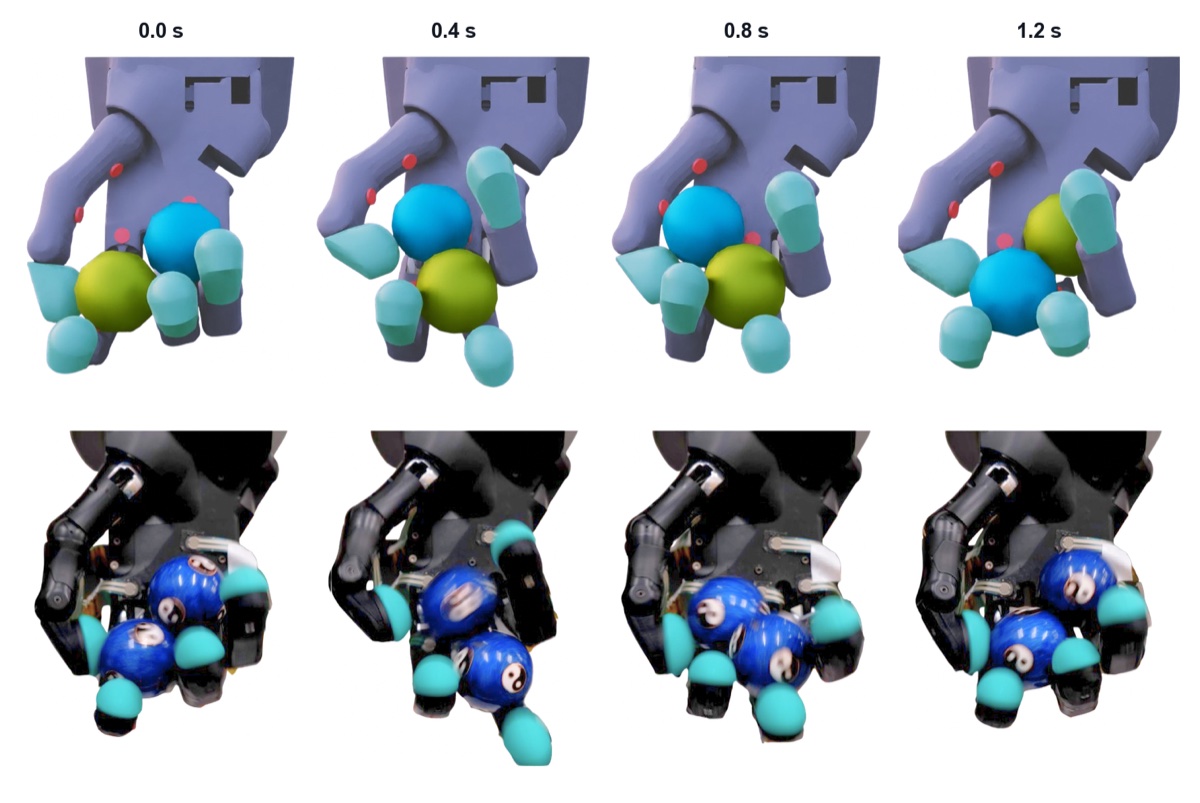
Robotic box folding.
MuJoCo simulation infrastructure for real-time box folding, object-state resets and trajectory execution. Controller-gain tuning and parallel parameter sweeps with mjbatch connect simulation to reinforcement-learning and data-collection pipelines.